

cholson
Member
I recently took on a DIY project to build a crane/slider combination based on the one by FloatCam (looked into purchasing this setup but IMO was way too much money).
The main points that I wanted in this design:
counter weight (just a whole lot of washers... meaning, a few boxes of them. cheaper than the other options i was looking at and gives super small adjustments)
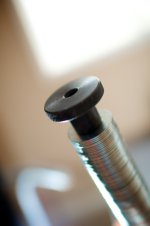
the main pivot point. went with ball bearings to ensure smooth crane motion
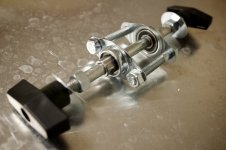
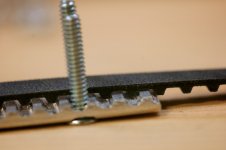
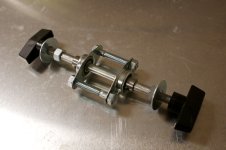
custom belt clamp. holds the belt that runs top/bottom of the slider and connects the camera carriage to the counter weight
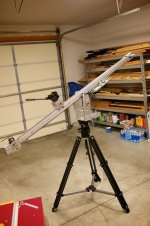
first time the rig was completed and setup... on the Kessler K-Pod and Hercules 2.0 head
added the Manfrotto 701HD
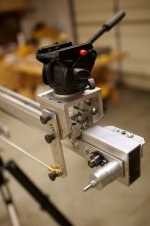
close-up of the motor and step down gears. setup to allow 1 RPM all the way up to 303 RPM motors from servocity
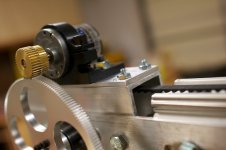
close-up of the carriage, stainless steel wheels, and slider purchased from PBC Linear
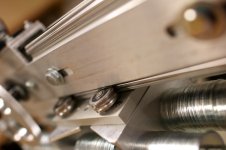
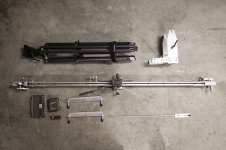
all the main pieces, including extra feet to allow the slider to be positioned on the ground (instead of a tripod) for really low slider shots
The main points that I wanted in this design:
- slider and crane/jib functionality in 1 device
- use a moving counter weight to balance both sides of slider. this provides more stability and allows the slider to be positioned on a single tripod no matter where the camera is at
- needed to be fairly simple construction because i don't have access to a CNC machine (yet)
- based on 2 sets of commercial sliders with ball bearing wheels rig for super smooth motion
- counter weight concept also allows for easy motion across the entire range of the slider. this type of setup allows the camera to move with a push from a single finger or small DC motor even when completely vertical
- all aluminum for strength yet still fairly lightweight
- quick release and knobs to help rapid setup and change from slider to crane/jib
- need to build a box to hold all of the electronic motor circuits (including a joystick to control the motion)
- add kill switches to stop the motor when it reaches the end
- finish work on a custom arduino controller (found some good resources, now just decide what features i need... and refresh my skills on how to solder circuit boards)
- replace the Kessler K-Pod tripod with smaller tripod (it's a great tripod but because of how i'm using it the minimum height puts the camera position too tall for horizontal slides)
- replace the slider wheels with rubber versions to be quieter
- design/purchase a custom hard case (plan on using LM cases)
counter weight (just a whole lot of washers... meaning, a few boxes of them. cheaper than the other options i was looking at and gives super small adjustments)
the main pivot point. went with ball bearings to ensure smooth crane motion
custom belt clamp. holds the belt that runs top/bottom of the slider and connects the camera carriage to the counter weight
first time the rig was completed and setup... on the Kessler K-Pod and Hercules 2.0 head
added the Manfrotto 701HD
close-up of the motor and step down gears. setup to allow 1 RPM all the way up to 303 RPM motors from servocity
close-up of the carriage, stainless steel wheels, and slider purchased from PBC Linear
all the main pieces, including extra feet to allow the slider to be positioned on the ground (instead of a tripod) for really low slider shots
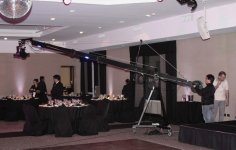
 it was so exciting to see the project move for the first time. a lot of work went into that moment and i wasn't sure if everything would even work. the parts from servocity really made that motorized aspect really fun and easy to deal with

 $195 mold charge plus $22 per bearing. Admittedly a small quantity of 25 wasn't going to garner a discount, but it is enlightening to find that it is possible to custom order a small quantity if you're willing to pay up.